Moment of inertia, abbreviated as \(I\), also called angular mass, rotational mass, or rotational inertia, measures the resists or change an object has to rotational acceleration about an axis. It is analogous to the mass of an object in linear motion and plays a similar role in rotational dynamics. The larger the moment of inretia the more difficult to try to get an object moving and the smaller the moment of inretia the easier of relatively easier to get an object moving. The moment of inertia depends on the distribution of mass around the axis of rotation. Objects with more mass concentrated farther from the axis of rotation have larger moments of inertia, while objects with mass distributed closer to the axis have smaller moments of inertia.
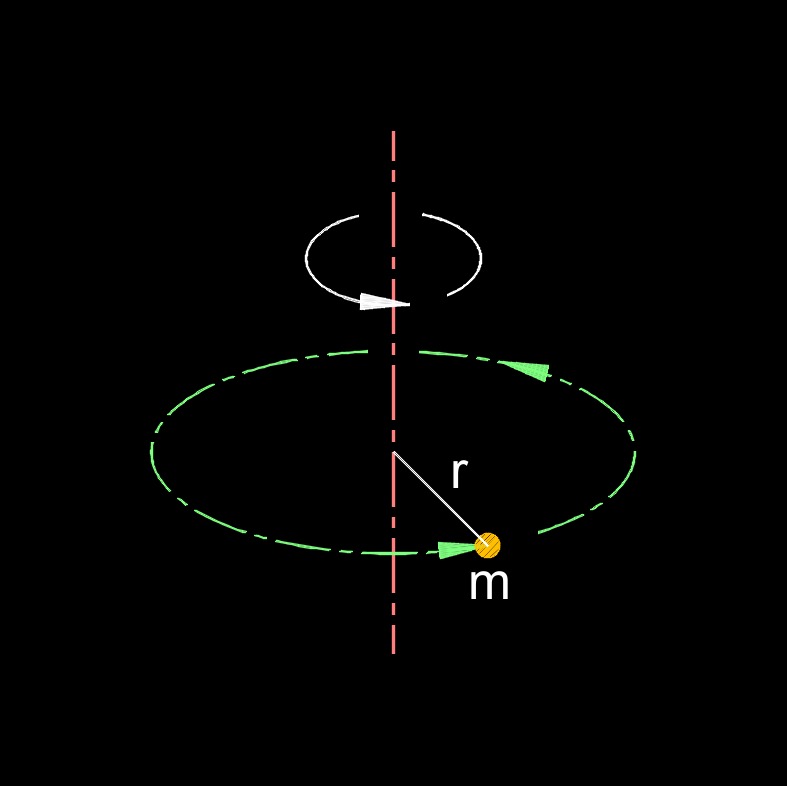 The moment of inertia varies depending on the shape and size of the object. For simple geometric shapes, such as cylinders, spheres, or rectangular solids, there are specific formulas to calculate their moments of inertia. For more complex objects, the moment of inertia can be found by integration, summing infinitesimally small mass elements throughout the object. Moment of inertia is a fundamental concept in rotational dynamics and provides insights into how objects rotate and respond to external torques.
Inertia is the tendency of an object in motion to remain in motion or an object at rest to remain at rest unless acted upon by a force. The larger the mass of an object the more resistance to change in motion than objects of a lesser mass. It is the tendency of objects to keep moving in a straight line at a constant velocity and direction forever unless acted upon by gravity or another force.
Moment of Inertia Types
- First Moment of Area (\(x^3\)), abbrev. as \(Q\) - The measurement of a shape's area cross-section relative to an axis, located in space.
- Second Moment of Area (\(x^4\)), abbrev. as \(I_x\), \(I_y\) - A geometric property of a area cross-section that quantifies its resistance to bending and deflection.
- Polar Second Moment of Area (\(x^4\)), abbrev. as \(J\), \(J_z\), also called polar moment of inertia - Describe the resistance of an objects cross-section to torsional (twisting) deformations. It is an extension of the concept of moment of inertia, which measures an object's resistance to rotational motion about a given axis. While the ordinary moment of inertia deals with bending or flexural deformations, the polar moment of inertia specifically quantifies an object's resistance to twisting.
- First Moment of Mass (\(x\)) - Used to locate the center of mass.
- Seond Moment of Mass (\(x^2\)) - Defined about a specified rotation axis.
- Products of Mass Inertia - Combine with mass moments of inertia in the inertia tensor equals moment of inertia matrix used for general three-dimensional rotation.
See Articles |
See Articles |